Home

A CUDA & OptiX path tracer with real-time progressive sampling, volumetric clouds and ray-marched shapes
What is RayON?
RayON is an educational and experimental path tracer written in C++17 and CUDA. It started as a re-implementation of the classic Ray Tracing in One Weekend series and grew into an interactive renderer that holds 60 frames per second while the camera moves and accumulates thousands of samples per pixel when it stops. It is used as teaching material in the ISC 302 High-Performance Computing course at HES-SO Valais.
Two GPU back-ends share one scene description and one GUI, each in an offline and an interactive flavour. No recompilation is needed to switch between them (-m 2 to -m 5):
OptiX (hardware ray tracing)
Triangles on the RT cores, custom intersectors for spheres, rectangles and SDF shapes, an AI denoiser for motion frames and a regulator that trades resolution for frame rate. The default when the OptiX SDK is found.
CUDA (software ray tracing)
One thread per pixel, a BVH traversed with an iterative stack, persistent random states and a float accumulation buffer that never leaves the GPU. Runs everywhere CUDA runs.
Interactive mode
SDL2 window with mouse orbit, pan and zoom, a Dear ImGui panel for every rendering parameter, scene switching with the arrow keys, HDR skies, and a button that writes the camera and the light settings back into the scene file.
CPU renderers archived
The original CPU rendering back-ends (sequential and multi-threaded) live on the legacy/cpu-renderer branch. The main branch is GPU only.
What it renders
- Materials: Lambertian, mirror, rough mirror, glass, GGX anisotropic conductors with measured complex IOR, thin-film interference, clear coat, area and sphere lights, and a volume material for clouds and smoke (delta tracking, Henyey–Greenstein phase function, volumetric shadow rays).
- Geometry: spheres, rectangles, triangles, Wavefront OBJ meshes with MTL materials and UV textures, procedurally displaced spheres, ten ray-marched signed distance primitives, and volumes shaped by a mesh, by procedural noise or by an OpenVDB density grid.
- Light transport: next event estimation with multiple importance sampling, a Sobol' low-discrepancy sampler with Owen scrambling, Russian roulette, adaptive (converged-pixel) sampling, a BVH built with the surface area heuristic.
- Scenes: a plain YAML format with 24 bundled examples, from a Cornell box to the Stanford bunny as a cumulus cloud.
Sample renders
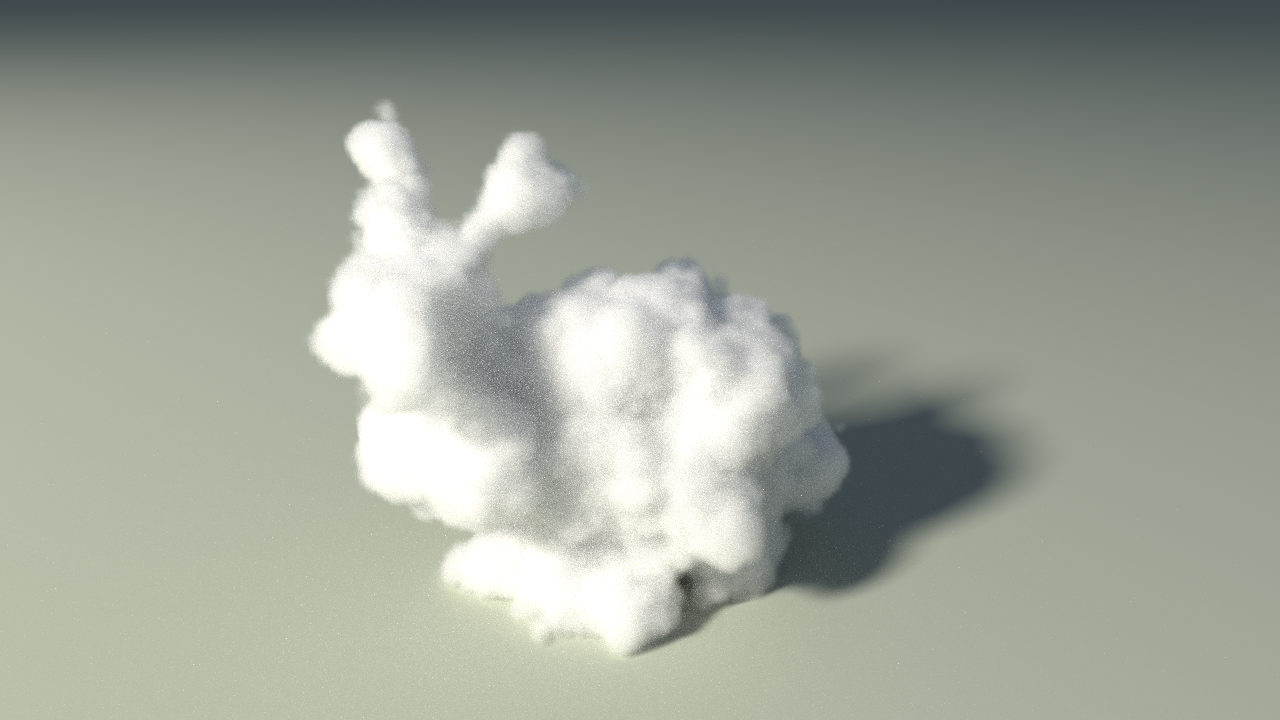
17_cloud_bunny.yaml.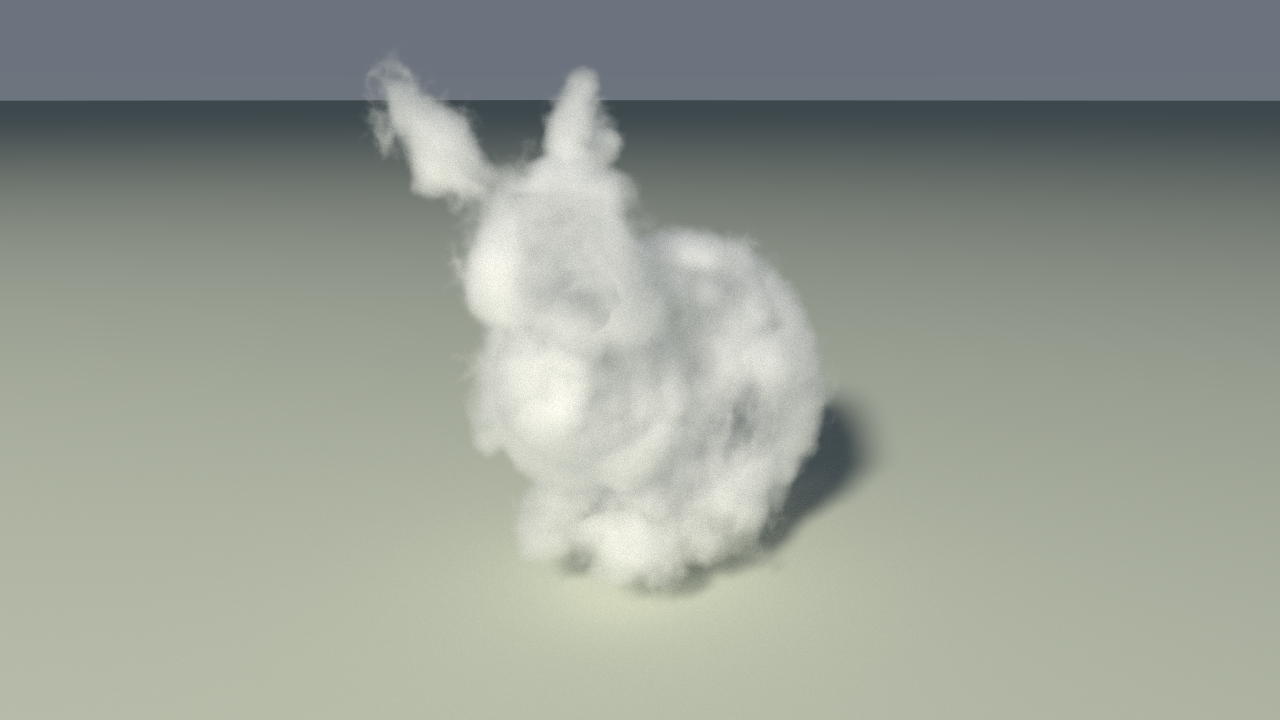
17_vdb_bunny.yaml.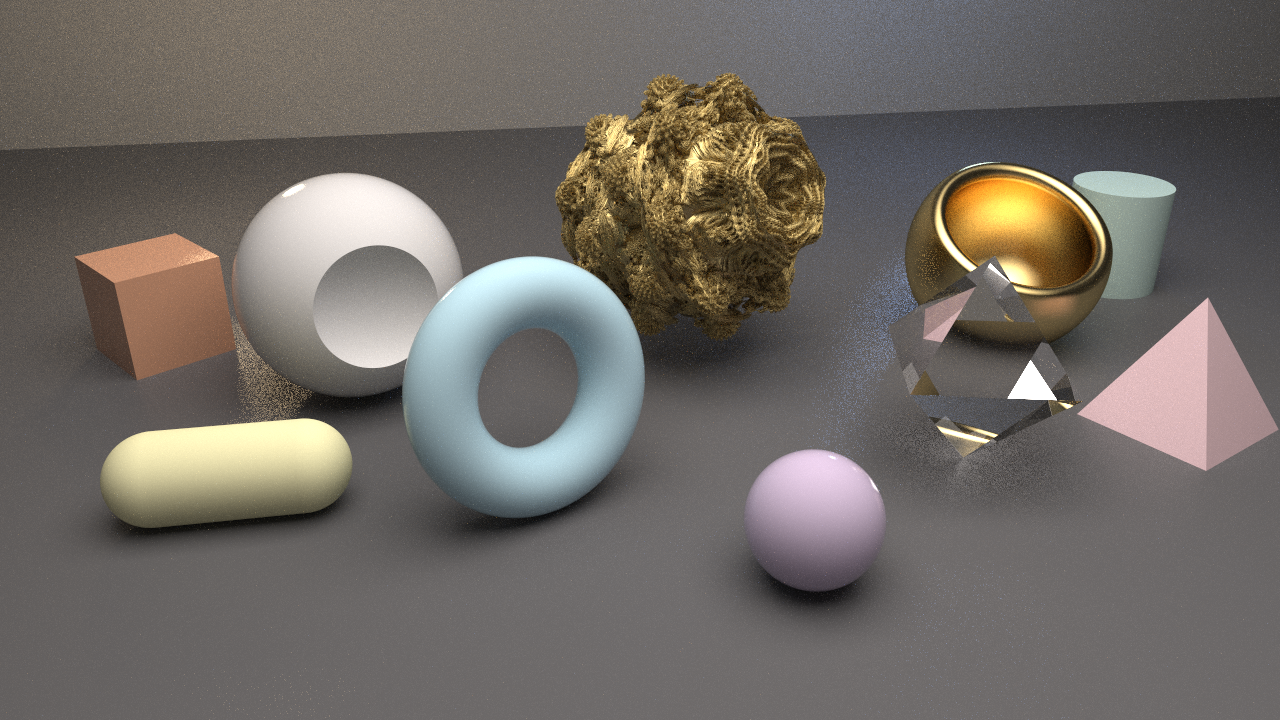
18_sdf_shapes.yaml.


Quick start
# Build (CMake ≥ 3.20, a C++17 compiler, the CUDA toolkit; SDL2 and the OptiX SDK are optional)
mkdir -p build && cd build
cmake .. --fresh
make -j$(nproc)

# Run from build/ — the OptiX programs and the HDR skies are found relative to this directory.
# Interactive OptiX when available, else interactive CUDA, else offline CUDA.
./rayon

# Pick a mode explicitly: 2 = CUDA offline, 3 = CUDA interactive, 4 = OptiX offline, 5 = OptiX interactive
./rayon -m 4 -s 512 -r 1080 --scene ../resources/scenes/17_cloud_bunny.yaml
See Getting Started for the full setup, the command-line options and the list of bundled scenes, or YAML Scene Format to write your own.
Explore the docs
| Section | What you'll find |
|---|---|
| How It Works | The math: rendering equation, materials, BVH, sampling, Sobol', MIS, optimisations |
| Architecture | Scene system, CUDA renderer internals, the progressive pipeline |
| Features | Interactive mode, YAML scenes, lights, volumes, SDF shapes, OBJ loading, HDR skies |
| Gallery | Renders from the bundled scenes |
| Performance | Benchmarks, speedups, tuning tips |
| Development History | How the project grew, commit by commit |